I am a Ph.D. candidate in Scalable Graphics, Vision, and Robotics (SGVR) Lab at KAIST advised by Prof. Sung-Eui Yoon. My research spans embodied AI, robotics, and 3D vision, aiming to build intelligent systems that perceive, reason, and act in complex environments.
Embodied AI and Robot Foundation Models
vision-language-action models, world models
3D Vision and Scene Generation
semantic scenes, depth, optical flow
Neural/Differentiable Rendering
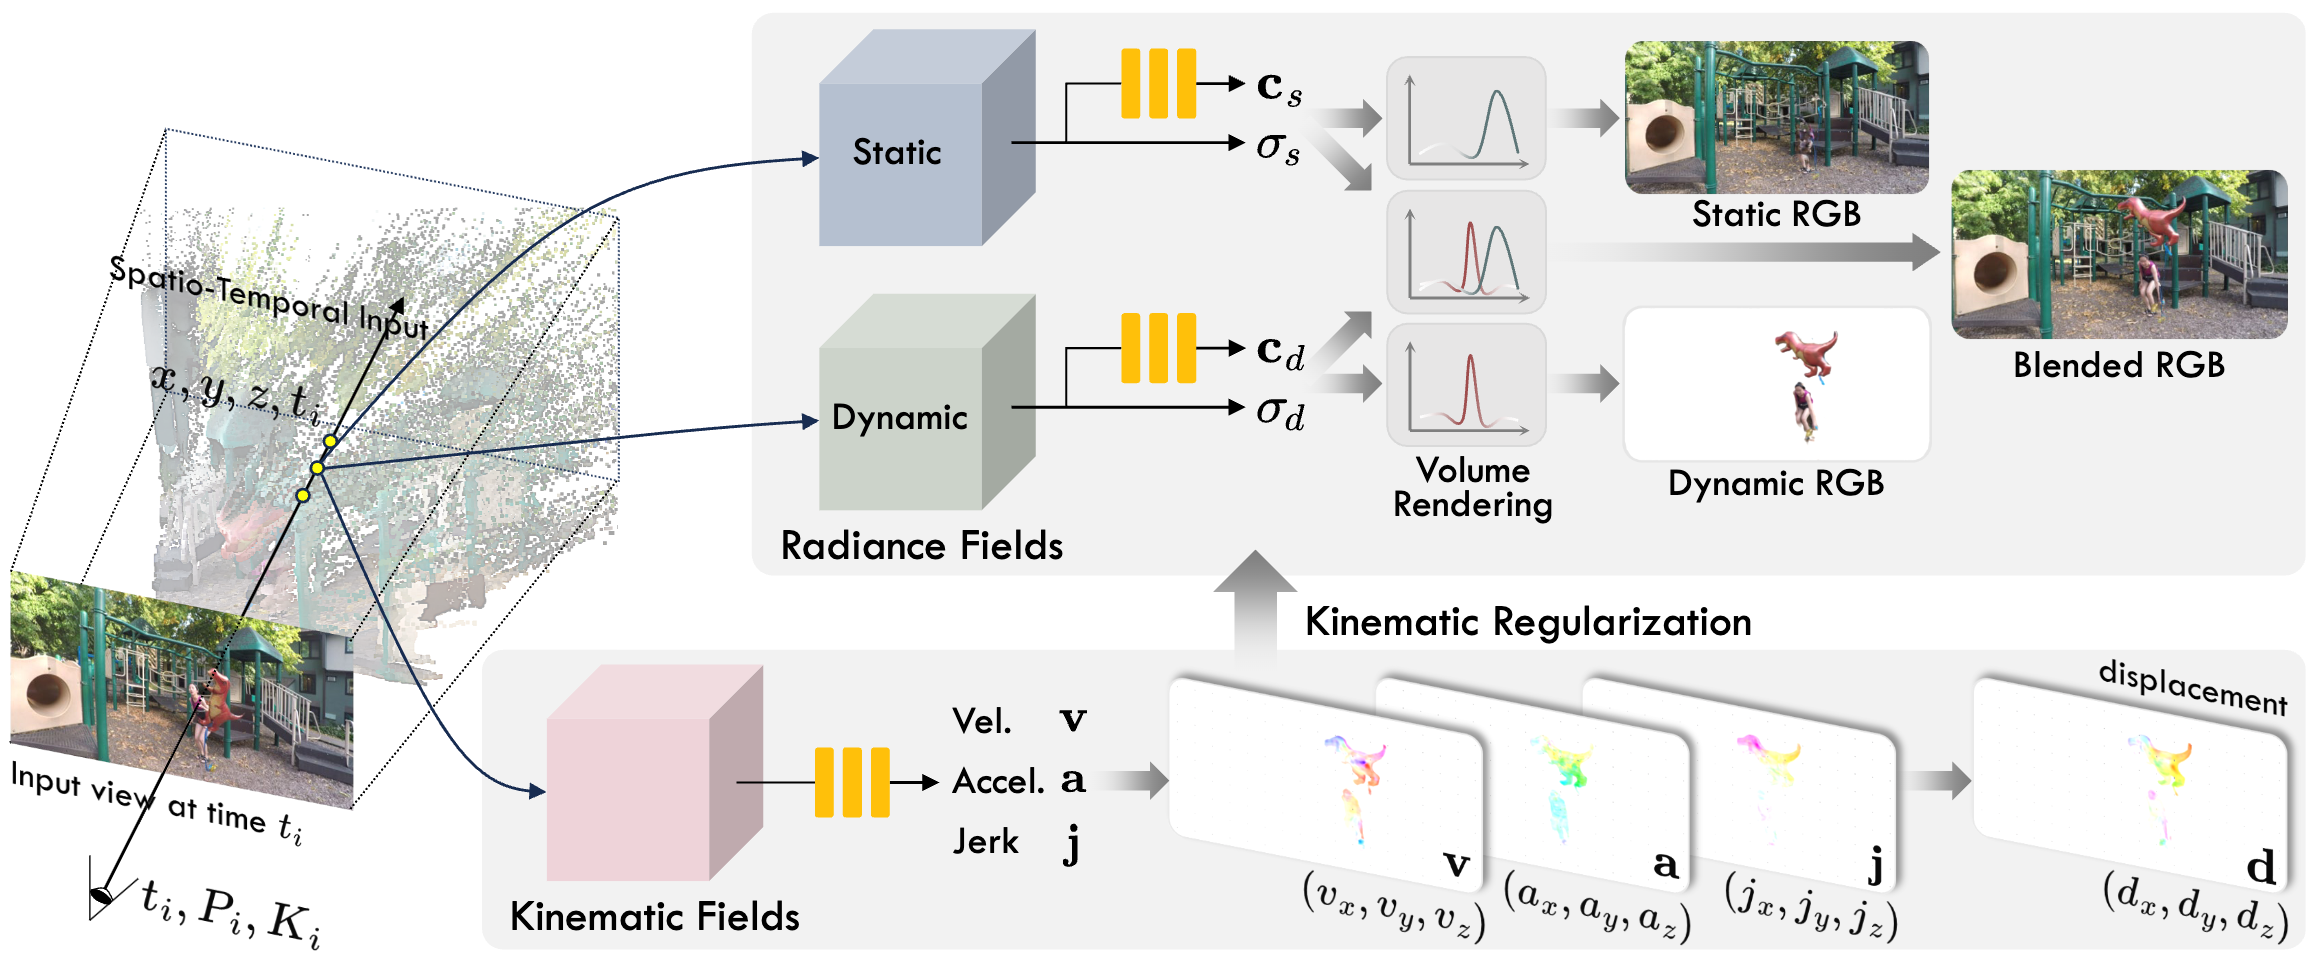
dynamic radiance fields, deformable Gaussian splatting
seb.lee [at] kaist.ac.kr
291 Daehak-ro, Yuseong-gu, Daejeon, Korea
B.S. in Automotive Engineering
Hanyang University
Mar. 2013 - Feb. 2020
Military service: 2017-2019
Incheon Science High School
Mar. 2011 - Feb. 2013
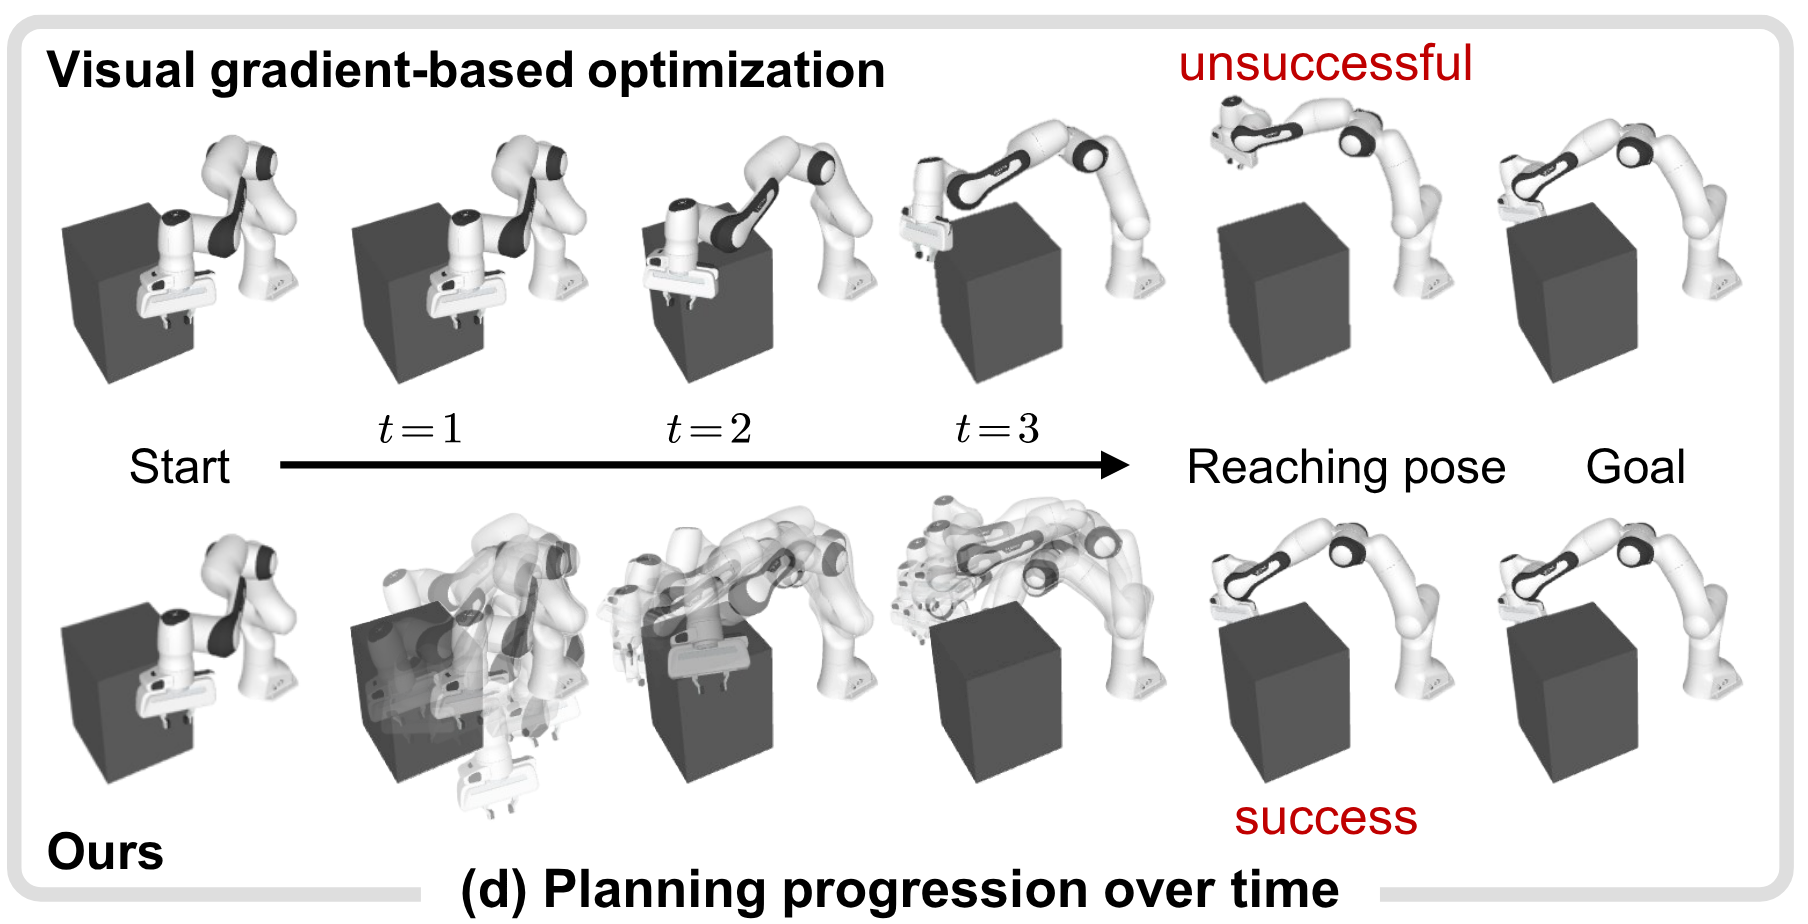
Visual-RRT: Finding Paths toward Visual-Goals via Differentiable Rendering
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2026
*Equal contribution
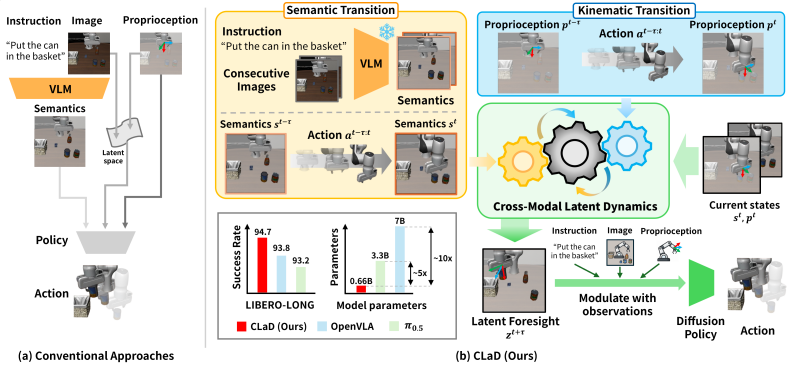
CLaD: Planning with Grounded Foresight via Cross-Modal Latent Dynamics
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2026
CrossTrack-UAV: A Real-World Dataset and Baseline for Cross-View Multi-Object Tracking using Fixed-Wing UAVs
IEEE Robotics and Automation Letters (RA-L) 2026
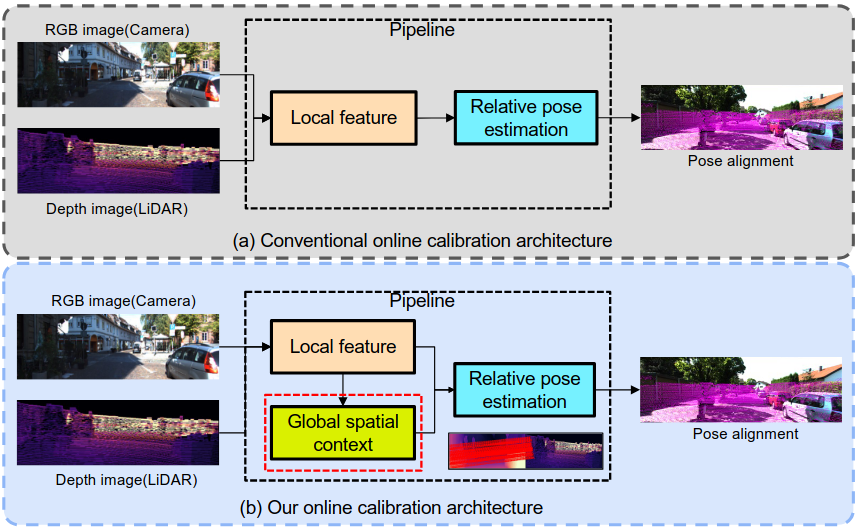
LiDAR-camera Online Calibration by Representing Local Feature and Global Spatial Context
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2024
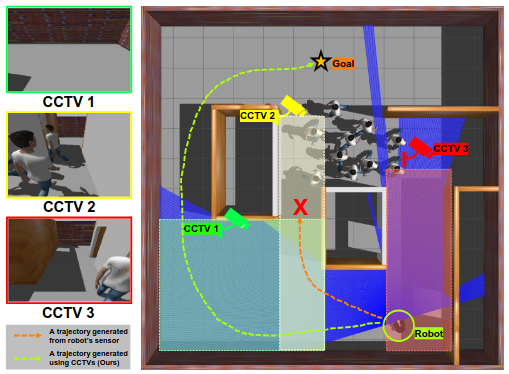
CCTV-Informed Human-Aware Robot Navigation in Crowded Indoor Environments
IEEE Robotics and Automation Letters (RA-L) 2024
Multi-Resolution Distillation for Self-Supervised Monocular Depth Estimation
Pattern Recognition Letters (PR-L) 2023
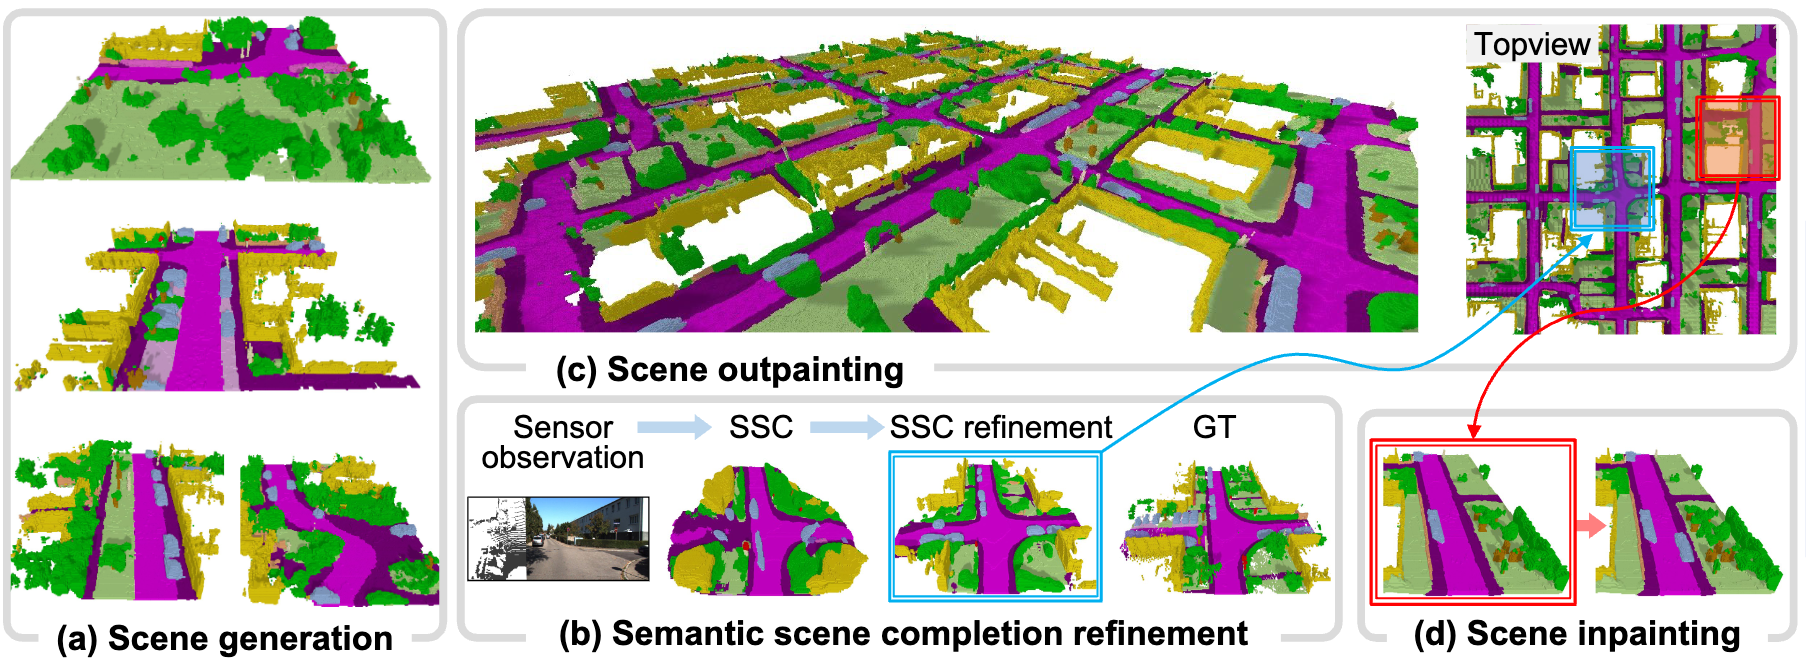
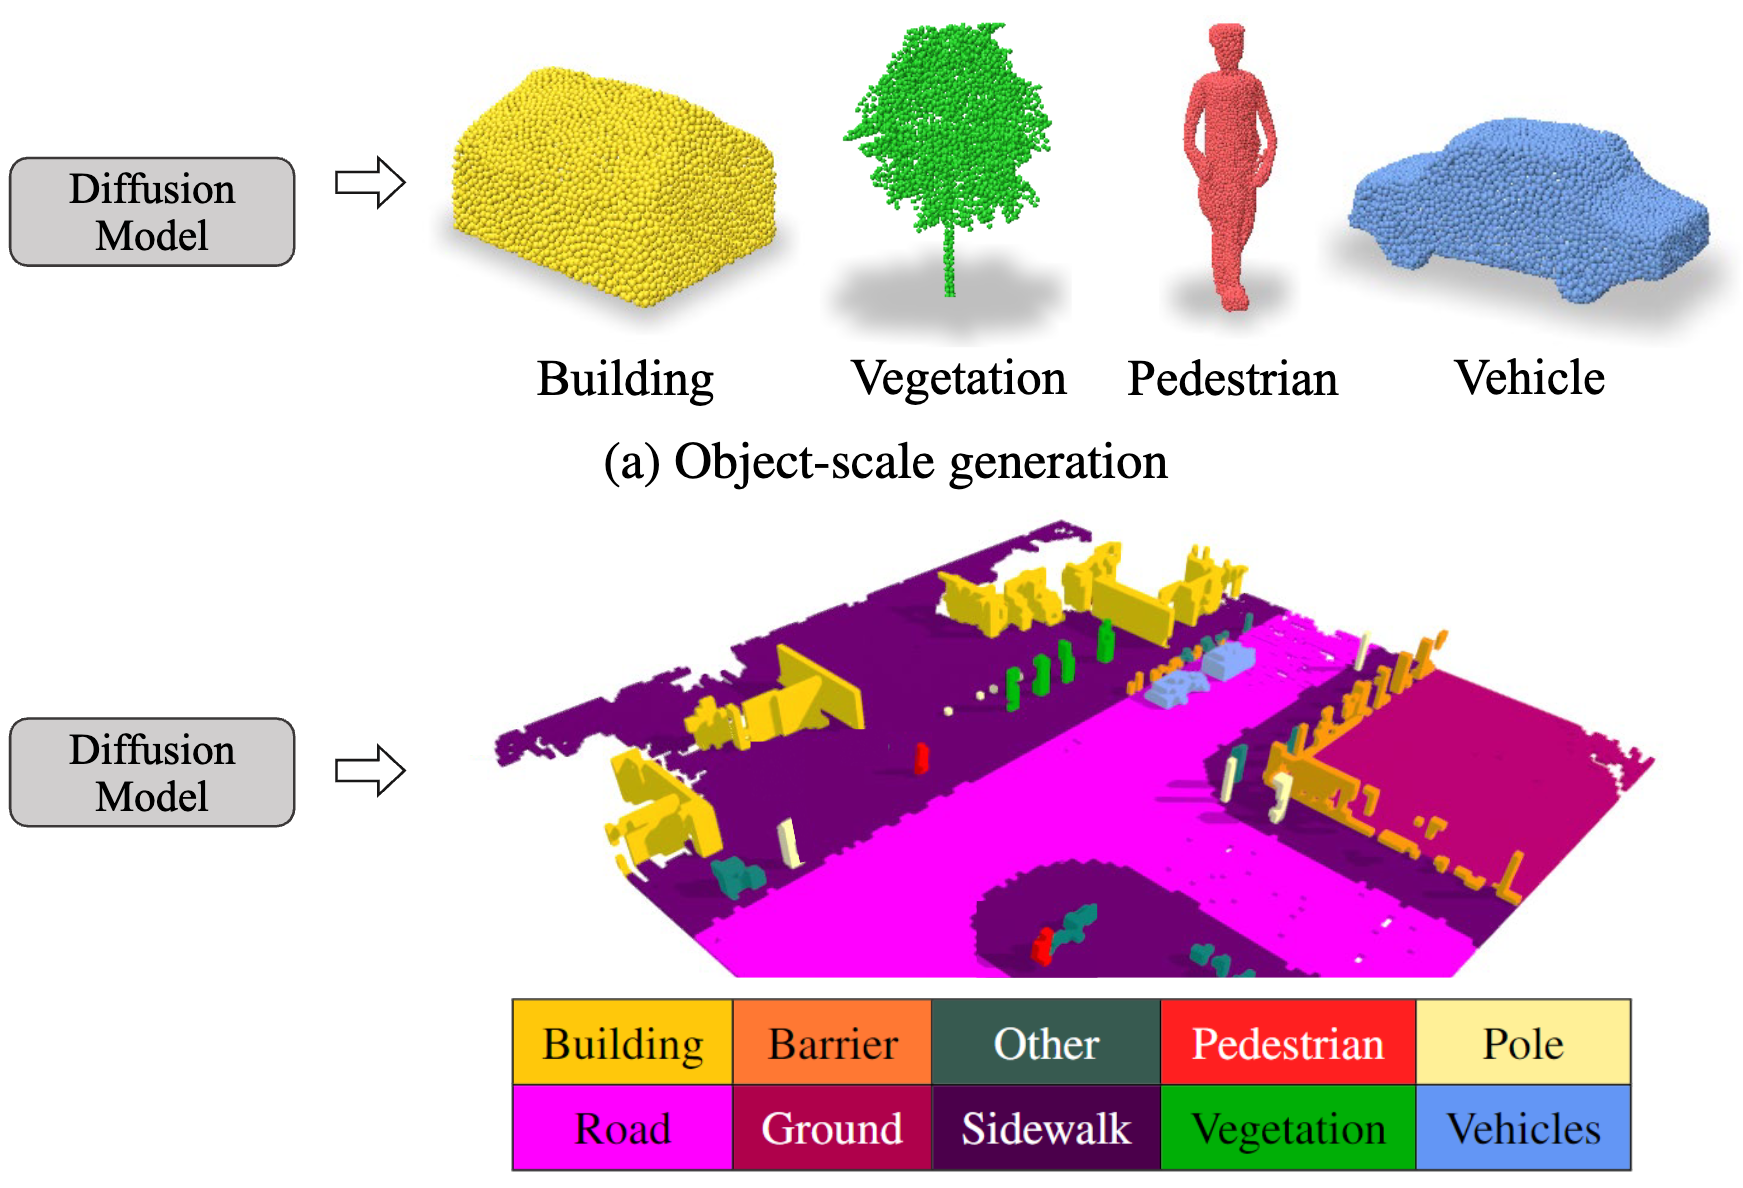
Diffusion Probabilistic Models for Scene-Scale 3D Categorical Data
Image Processing and Image Understanding (IPIU) 2023
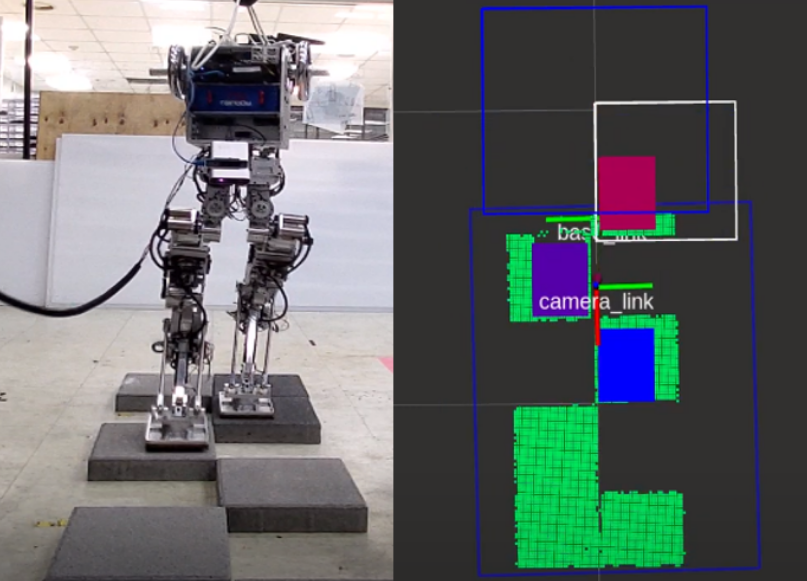
Dynamic Humanoid Locomotion Over Rough Terrain With Streamlined Perception-Control Pipeline
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2021
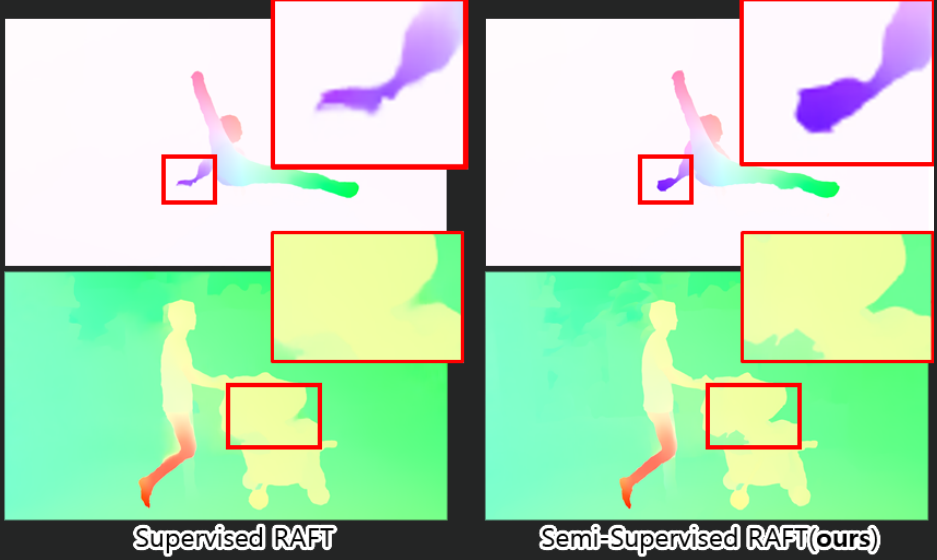
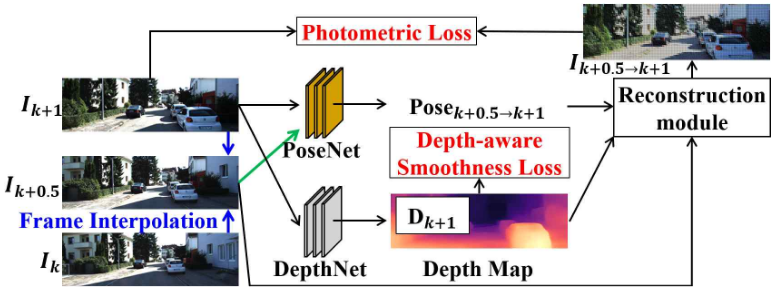
Self-Supervised Visual Odometry via Frame Interpolation
Korea Robotics Society Annual Conference (KRoC) 2021